Shunichi Sekiguchi
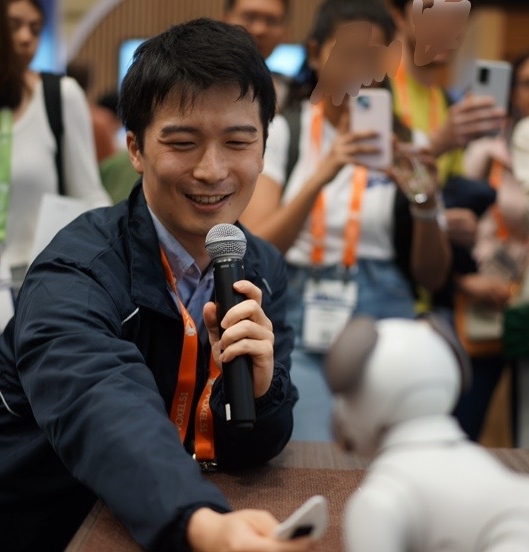
I’m a research engineer at Sony Group Corporation’s R&D Center and a Ph.D. candidate at Keio University.
My research interests center on human-in-the-loop systems, particularly how human feedback and AI can work together to make learning more efficient, reliable, and aligned with human preferences.
At Sony, I developed and released an object-grasping capability for aibo, contributed to the development of nnablaRL, and am currently applying black-box optimization to a wide range of projects across Sony to improve operational efficiency.
My master’s research focused on human-following robots. My Ph.D. research explores human-in-the-loop approaches to reinforcement learning and robotic systems. You can find more details on my CV and Publications pages.
News
Our paper, Human-VLM Collaborative Labeling Framework with Consistency-Guided Viewpoint Optimization for Preference-Based Reinforcement Learning, has been accepted for publication in IEEE Access. (2026)
aibo PICKS UP ANYTHING has been released!
My control theory library, PythonLinearNonlinearControl, has reached 1,000 stars on GitHub!
- Presented aibo PICKS UP ANYTHING at the Sony booth during CVPR 2024.
Shared our research, Naming Objects for Vision-and-Language Manipulation. (2023)
- Presented nnablaRL at the Sony booth during NeurIPS 2022.
- Released nnablaRL, an open-source reinforcement learning library. See the release announcement for more information. (2021)