Page Not Found
Page not found. Your pixels are in another canvas.
A list of all the posts and pages found on the site. For you robots out there is an XML version available for digesting as well.
Page not found. Your pixels are in another canvas.
About me
This is a page not in th emain menu
Published in Robotics and Autonomous Systems, 2020
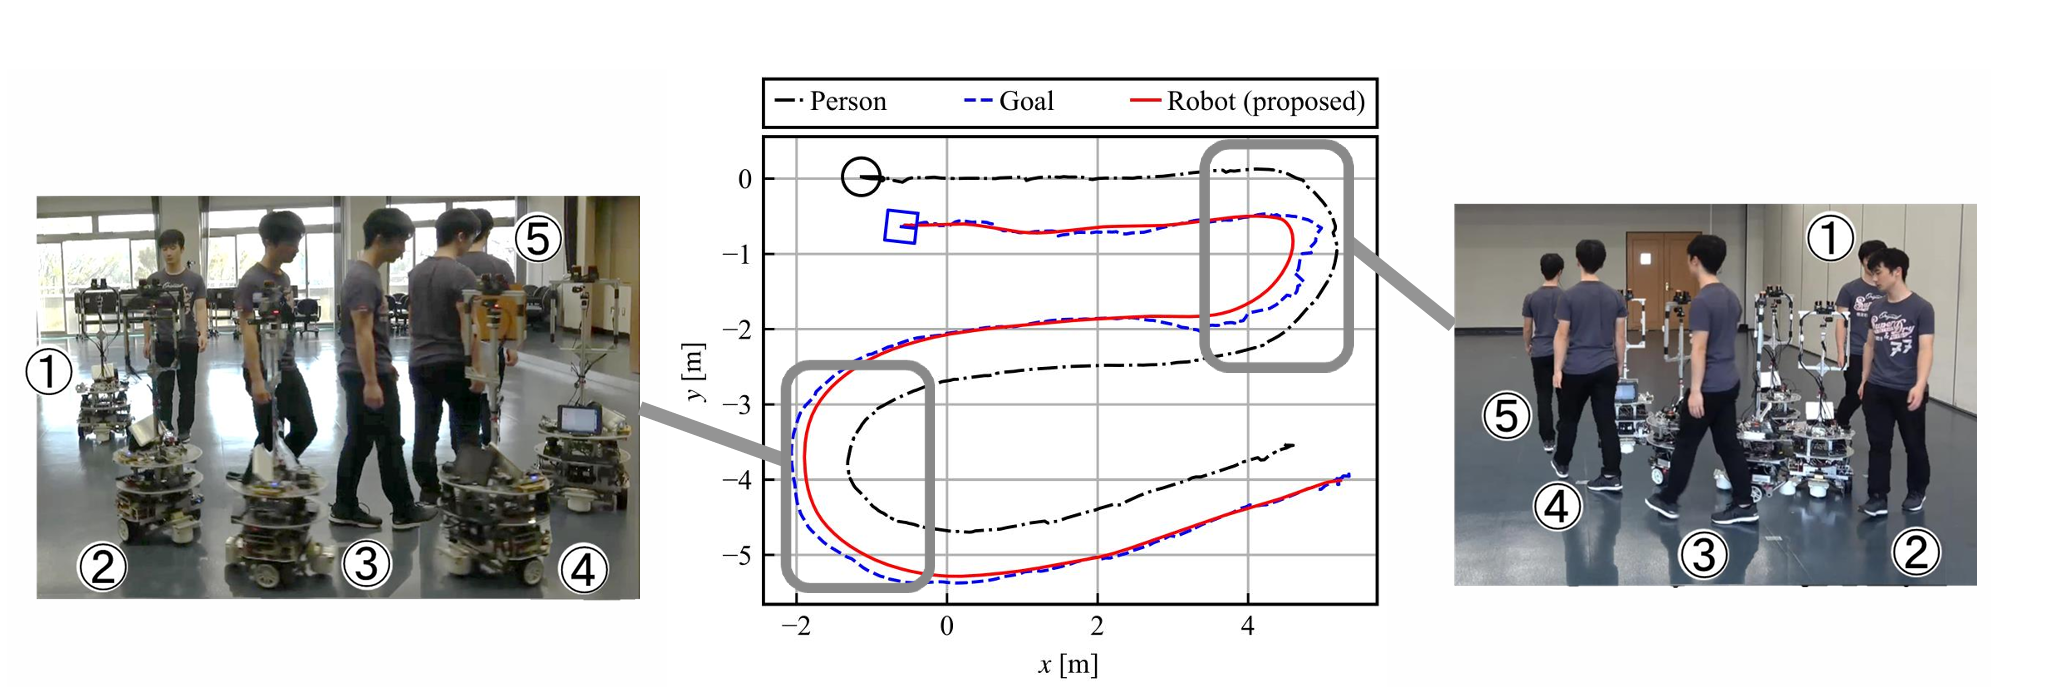
We developed an adaptive nonlinear model predictive controller for a two-wheeled companion robot. By adjusting its cost-function weights according to the human-robot distance, the robot can follow people smoothly through situations such as U-turns without obstructing them.
Published in 2021 IEEE International Conference on Robotics and Automation (ICRA), 2021
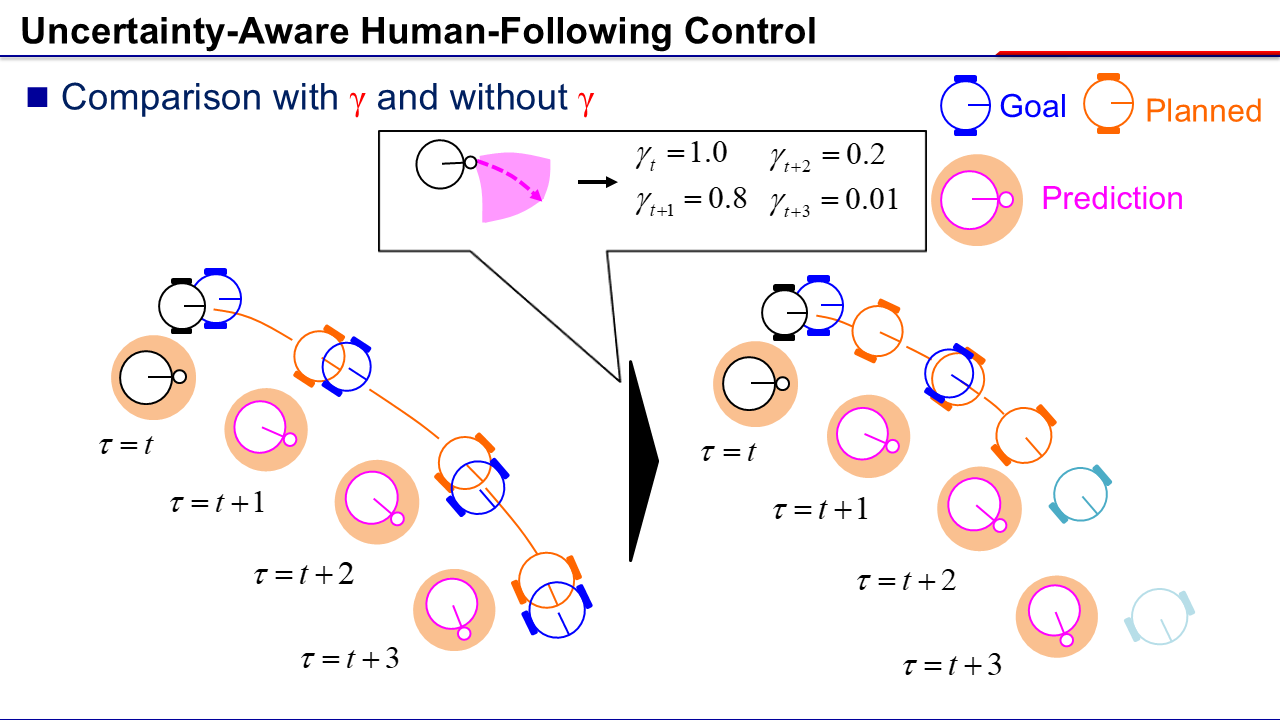
We developed an uncertainty-aware nonlinear model predictive controller that adjusts how strongly a companion robot trusts predicted human motion. This enables proactive following while avoiding overconfident movements that could obstruct the person or cause the robot to fall behind.
Published in arxiv preprint, 2023
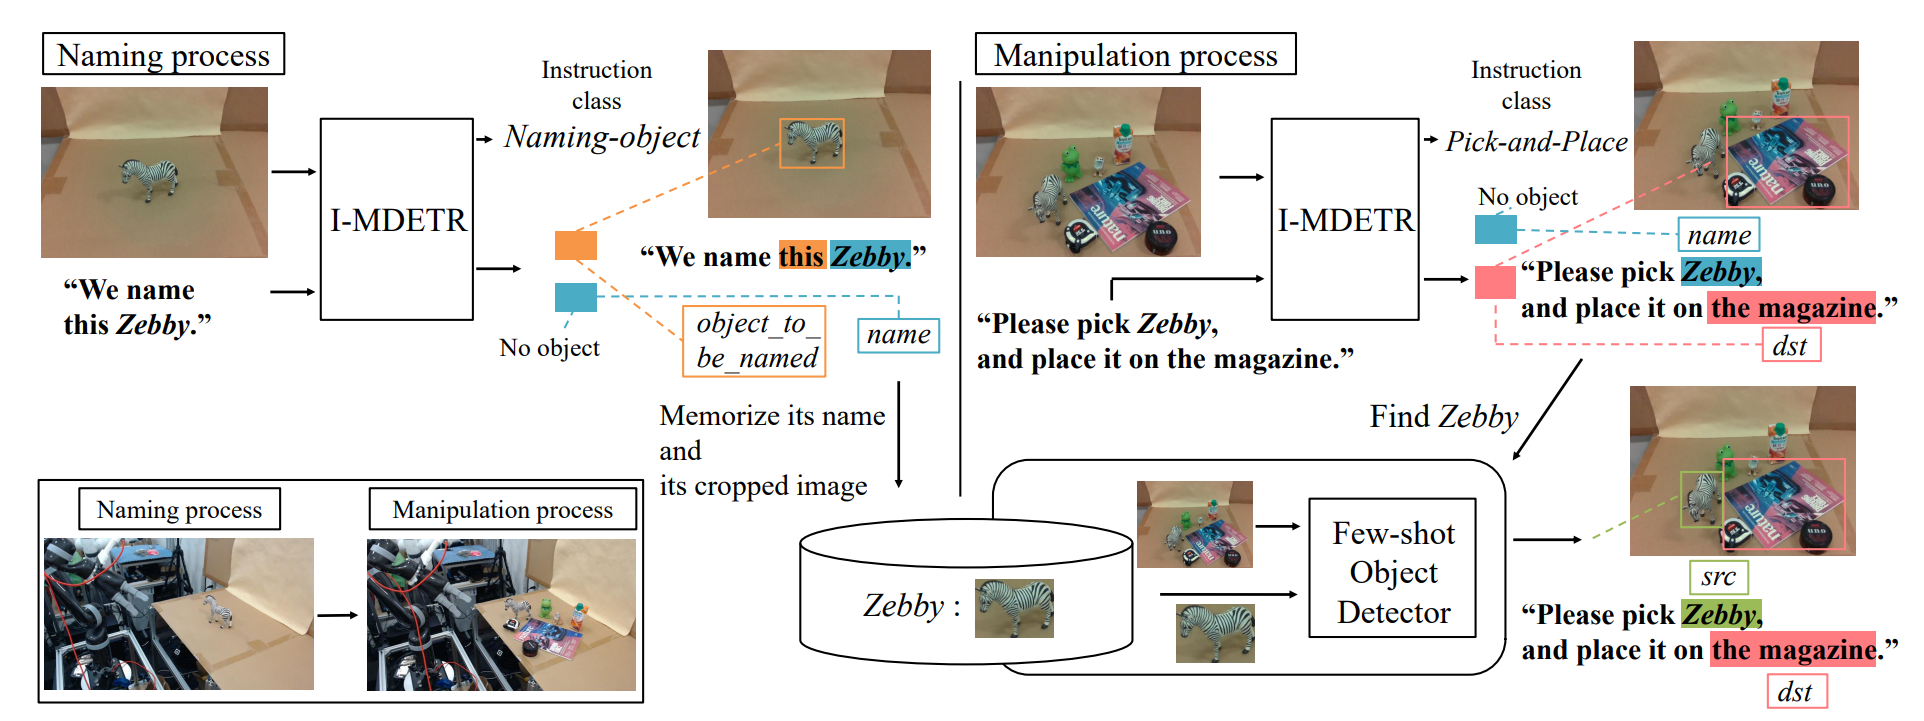
We developed a vision-and-language manipulation system that lets users assign unique names to objects before giving instructions. By remembering both the name and appearance, the system reduces ambiguity in later pick-and-place commands; in experiments, it improved task success by 31% under ambiguous instructions.
Published in IEEE Access, 2026
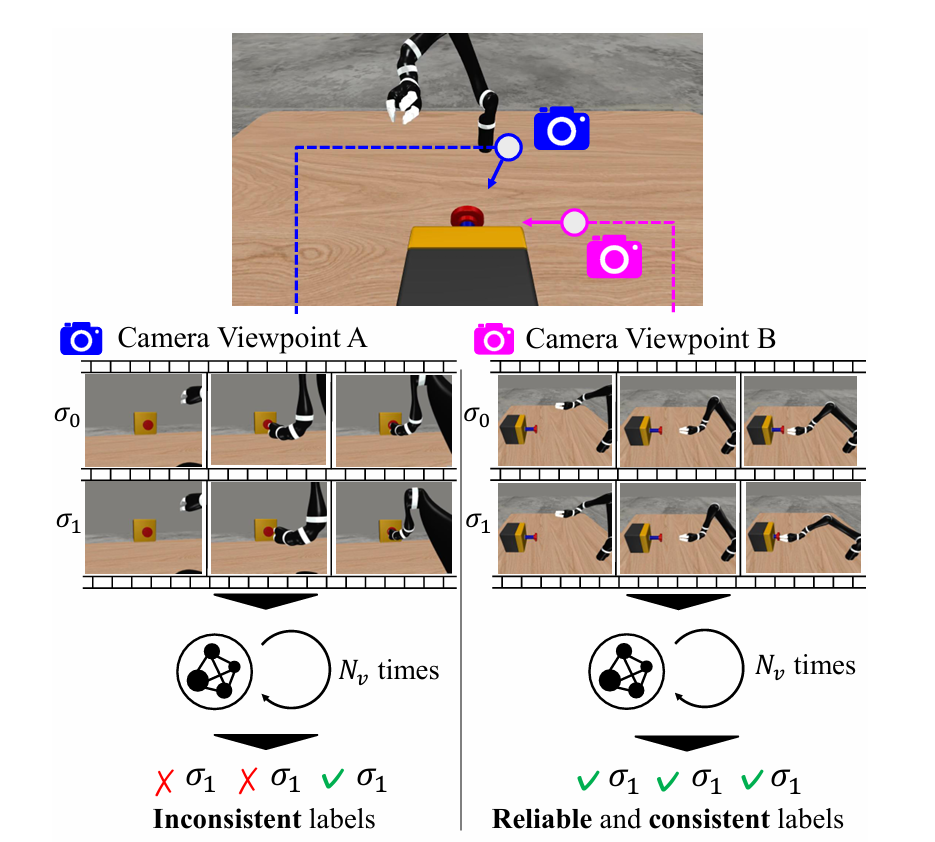
We developed a human-VLM collaborative framework for preference labeling in reinforcement learning. It uses label consistency to estimate VLM reliability and Bayesian optimization to select camera viewpoints, improving annotation quality while reducing the need for human feedback.