Uncertainty-aware Non-linear Model Predictive Control for Human-following Companion Robot
Published in 2021 IEEE International Conference on Robotics and Automation (ICRA), 2021
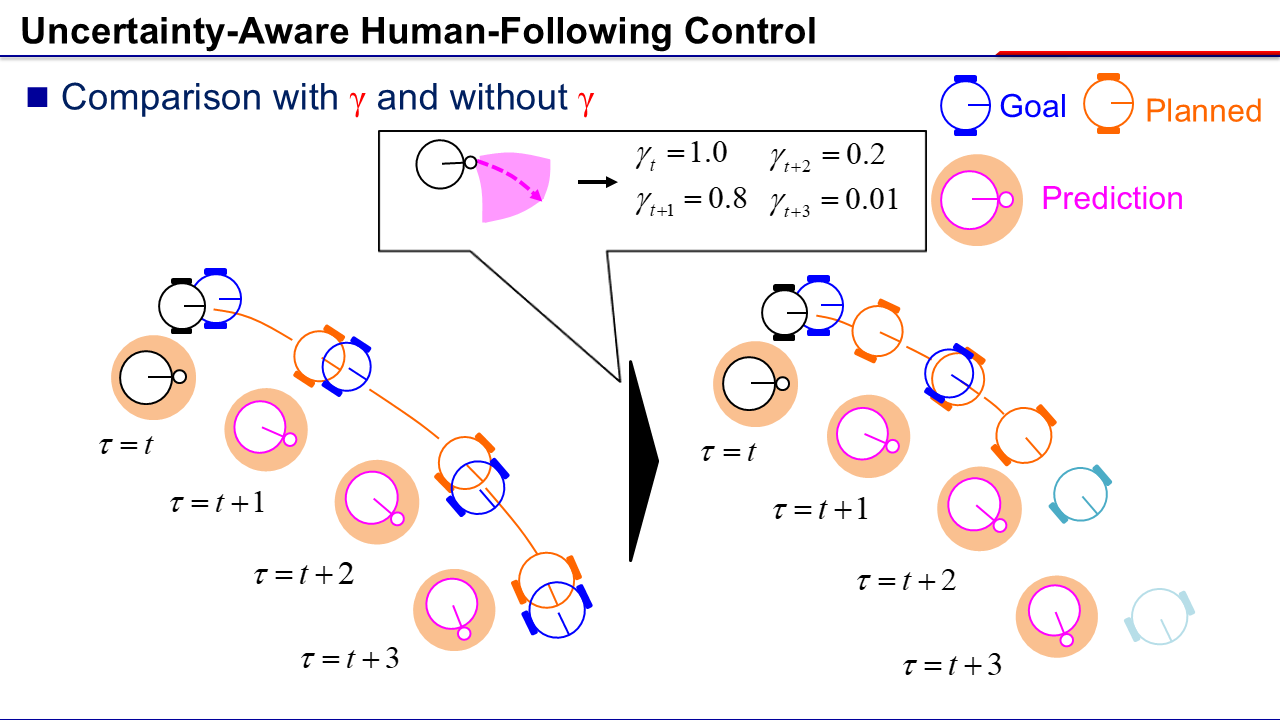
We developed an uncertainty-aware nonlinear model predictive controller that adjusts how strongly a companion robot trusts predicted human motion. This enables proactive following while avoiding overconfident movements that could obstruct the person or cause the robot to fall behind.