Human-friendly control system design for two-wheeled service robot with optimal control approach
Published in Robotics and Autonomous Systems, 2020
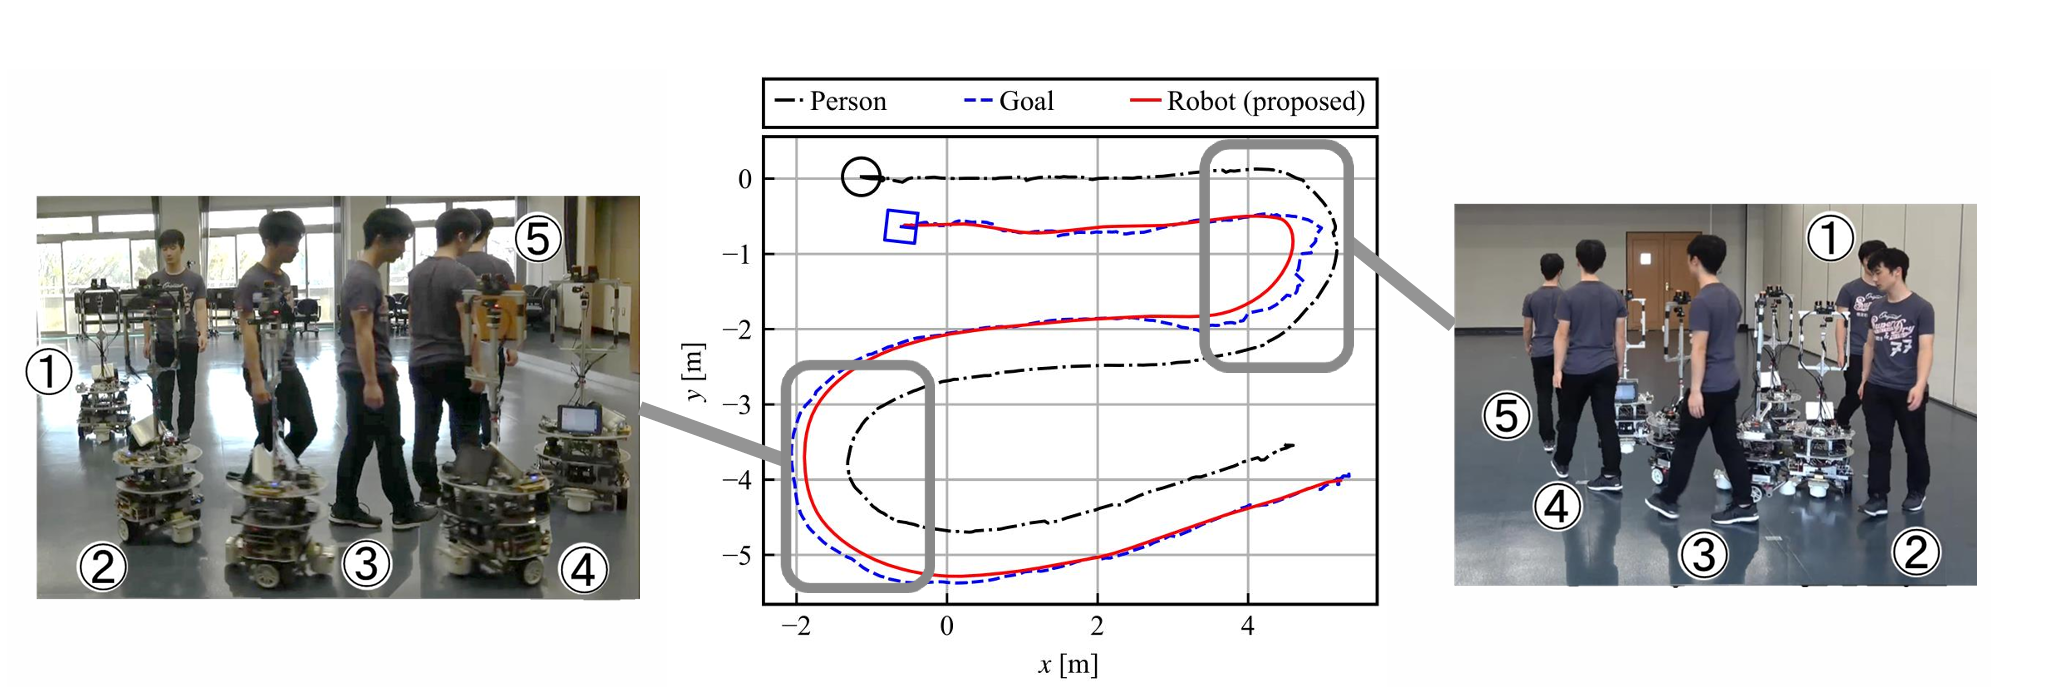
We developed an adaptive nonlinear model predictive controller for a two-wheeled companion robot. By adjusting its cost-function weights according to the human-robot distance, the robot can follow people smoothly through situations such as U-turns without obstructing them.